My Notebook

Stories through my life. The good times and of course, the bad times.

A visit to FarmRobo

A visit to FarmRobo

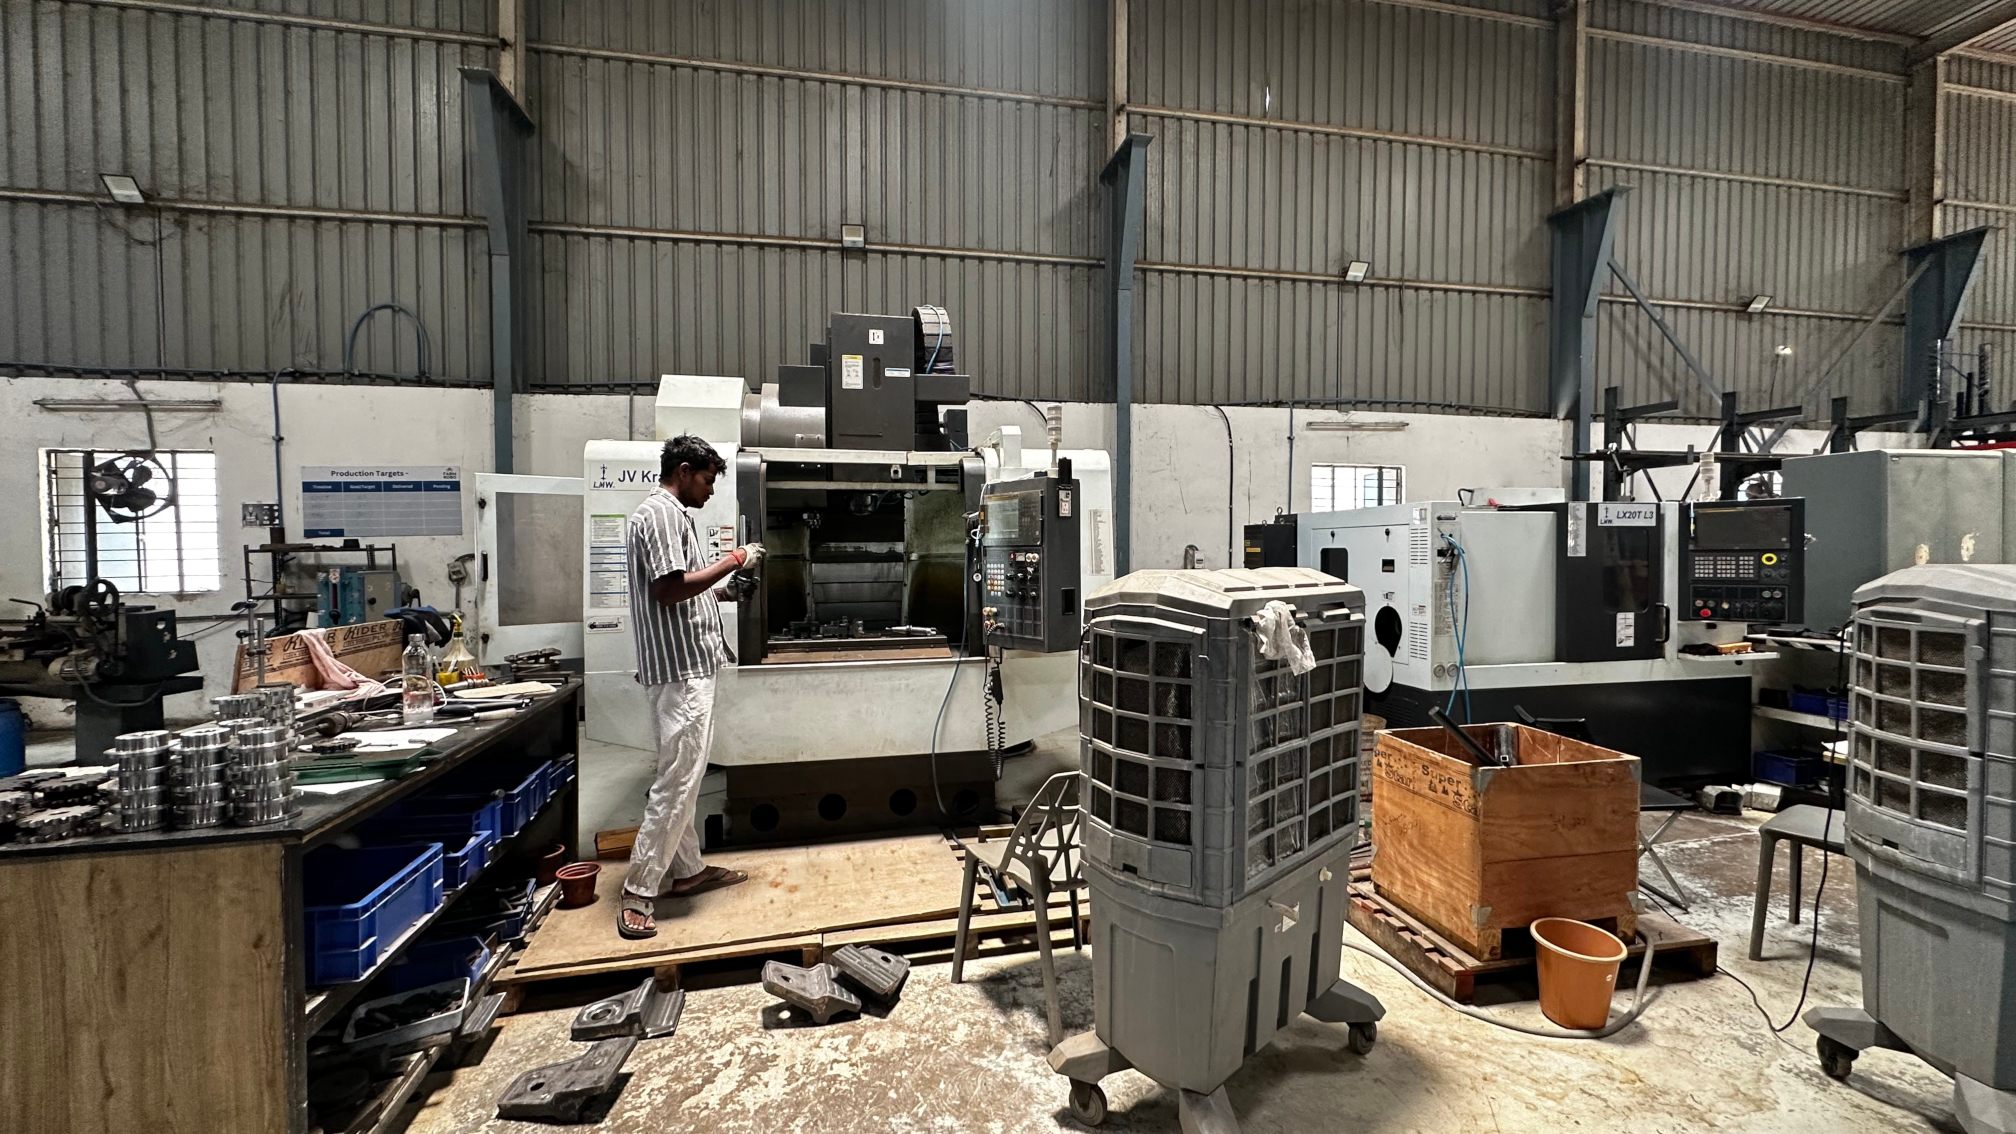
Some time ago, I had the opportunity to visit FarmRobo, in Hyderabad. They are solving the agritech automation problem. It's pretty close to home as Madhya Pradesh, my state of residence, is one of the most agriculturally intensive states in the country. Another reason it is near to my heart is because growing crops in a clean, healthy and efficient way is a lot harder than it seems. I must admit, their outreach and manufacturing capability was formidable. They are developing a platform based solution, where they have a main robot, their flagship R1V2, with several attachments for tilling, watering, spraying, et cetera. It's surely an interesting approach. I don't think they have the best form factor. They have derived the design from what is basically a regular tractor that is used in farms and scaled it down. I think the most glaring issue is that they don't have a massive amount of ground clearance. They advertise 170 mm of ground clearance, which sounds like a lot, but the ground clearance of the vehicle it is hoping to replace is about 300 mm and pushing up to 500 mm. Another pitfall the R1 V2 has is a max speed of 9 kmph. Maybe it makes sense for very extensive tasks like sowing, but for something like spraying or carrying items around, it's just abysmally slow. They also have a built in battery that is 8 kWh and additional batteries that can be replaced of about 2 kWh (I couldn't find anything about the 2kWh batteries in their brochures or the website). Either it should be the other way round, where one can swap the larger batteries, or it just shouldn't have an inbuilt battery, as that basically renders the continuous utilization of one, or a fleet of vehicles impossible. As a farmer, investing about Rs. 12,00,000 into a piece of equipment that I can only use for about 6 hours a day. It would be a significant advantage for me if I could attain the maximum possible utilization, whether I am using it myself or lending it out as a service. As for their electronics setup, they are using a combination of a Pixhawk (or similar) with a Jetson Nano, along with RTK based GPS and some cameras, probably running something like iNav or something similar. I think a better way to solve the problem and be more effective would be to make the system even more modular while keeping the dirt away from more thoughtful design. Would it increase the price? Perhaps. But it would also help with repairability and support, especially if and when something goes wrong on the field. I think that trade off would be worth it. I especially think that integrating the different attachments into modules that are rigidly connected and are a lot more high tech (after all, agritech isn't just about locomotion) would increase the yield a lot more than what is currently achievable and hence the trade off compared to cheap labour would be a lot more justified. They also do offer a manually controlled version without any of the fancy computing for about 33% less than the price of the original. Either way, I do believe they will sooner or later improve their tech vastly. They were even experimenting with utilizing drones. I, as an FPV pilot and as someone familiar with drone tech, do not believe that utilizing drones for low fidelity tasks like spraying is the most efficient or an efficient way to use them. They can be better used in intricate environments where their agility is TRULY needed. I also loved this very bare and industrious looking robot with tracks instead of wheels. If I recall correctly, this was what they had first started with as an experimental vehicle. Overall, I do think they are doing something very formidable and innovative indeed. I also really enjoyed having a look into their manufacturing building. Agritech is an emerging sector in India only if done right. It's more or less everything on hard mode due to low labour costs. Thank you to FarmRobo for the opportunity! Sid.

Read Entry →
A burnt motor and a tree. One terrible drone race.

A burnt motor and a tree. One terrible drone race.

I was recently in Nagpur, attending the drone race held at VNIT. This was my second drone race that I attended irl. During qualifying, I had the 5th fastest time for 3 consecutive laps and I was pretty happy with it. I feel like the only thing I should have changed was the camera angle. I was running a 50 degree fixed mount, and let's just say that was BAD. The real issue is that a higher camera angle lets you add more horizontal power, allowing you to take your turns tighter and be faster in a straight line (adding more power with a low camera angle, means you see a lot more of the ground than the gates you are trying to pass through). Regardless, I wasn't that far behind. Then came race day, and the day where I wouldn't be so lucky. We sharted off with the heats. I was competing against the guy who qualified 4th. He made a mistake and hance he was out, leading me to win the first heat. Then came the second heat, and I was up against the 1st and 4th seed. At the end of the first lap, I was running second. Coming around the the start gate, I had a mid air colision with the 4th seed, who was running just behind me. I got up, thinking at least I'd give it my best. The drone sounded funny, but I kept going. Halfway through the third lap, I fall out of the sky and I see smoke come out of one of my motors. I got eliminated once. I swap my electronics to the spare frame and motors in a frenzy. The next heat was with a brand new setup. I took my time to get up to the mark and won the heat regardless. That felt good. Then came the redeption bracket semifinals. I was against the first and the fifth seed. I had to win this one to secure my position in the top 4. The liftoff tone sounded, and I went up in the air. I caught everyone up in the outlapm and was going to be the first one to start the lap. And then, while trying to line myself up at a high speed, I hit a tree. A damn tree. And I got STUCK in the tree. Yup, and that's how I ended up placing 8th. I expected a lot more partly because I fly very fast on the simulator. Could have gotten at least 4th place, but better luck next time I guess. Sid, signing off.

Read Entry →
My first drone race.

My first drone race.

I’m disappointed. At the moment, I’m on the flight returning from Mumbai. The trip was amazing; the race, not so much. Did I crash a lot of times? Yes. Am I happy about it? No. But did I learn a lot? Yes. The first day, we had practice and the track was fairly flowy. But then, late into the afternoon after about six packs, I hit a gate with metal pipes going full throttle. It happened so fast, I didn't see it coming at ALL. I went out to the field to see where my drone was and found the bottom part, battery still plugged in, stack and motors intact, but no top plate. I looked around frantically and finally found the assembly about 10 meters from the gate. The aluminum standoffs had SHEARED OFF. The VTX was still attached to the top plate, but I could not find the receiver ANYWHERE. The solder joints had ripped off CLEAN. I was baffled. I frantically borrowed a receiver from someone (thanks Ninja FPV) and soldered it on. Somehow the VTX was still working and the camera wasn't damaged. I got a few packs in and ended the day with a crash. When I got back to the apartment, I decided to get some sleep. After a good night’s rest, I got to building a new drone with the parts I’d bought the previous day and a few spares. I was halfway done when I had to leave for the venue. Qualifying was starting and I had to hit top 16 to be eligible for the race. When I tried to fly the old drone, it DID NOT turn on. The motors beeped, but the ESC did not connect to the flight controller. The FC had no power. I checked the wires, but it wasn't that, the FC was just broken. This was full on panic. I scrambled to finish my spare drone, borrowing a VTX from someone else (thanks Hunt FPV). I eventually managed to queue myself for the very last round of qualification. I asked Adile FPV (thanks Adile for the lights too!) to spot me. My nerves were not helping. The beeper goes off. First lap: a slight bobble in the dive gate, but a 20.2-second lap. Amazing. Second lap: I crash, manage to recover, and get a 21.4. Even better. I just needed to get the third lap in and I would comfortably qualify in the top 10. The third lap, at the dive gate, I hit the gate. I manage to get back up, but as I go on the straight after the dive, I careen straight into the ground. The battery ejections, and it is OVER. I cannot even compete. Dejected, I went back to the apartment. I really hope I have a better race next time. I do love this hobby though, especially how much it involves swiping credit cards. Maybe 2025 just isn't my year. I hope 2026 will be better. Sid, signing off.

Read Entry →
WRO '25: The Worst Luck

WRO '25: The Worst Luck

Here we are again. After the high hopes of my last entry, the competition didn't exactly go to plan. In fact, we couldn't even participate. We arrived at the venue feeling confident. We had a solid bot, respectable software, and, honestly, the best hardware design of anyone present. We were running LiDAR, something only two other teams decided to do. First on the list was the technical interview, and it went perfectly. The judges were so engaged with our design and software stack that the five minute slot turned into a fifteen minute deep dive. We were on a roll. Then came the practice rounds. We plugged in the battery and waited for the Raspberry Pi to boot and connect via SSH. Nothing. We tried fifteen different times, forfeiting practice rounds just to troubleshoot. We eventually left the venue early, since Day 1 was only for practice, hoping to fix it at the hotel. We tried everything to get that Pi to connect. Finally, I tried to read the SD card directly. Nothing on macOS. I swapped to my Linux machine. Still nothing. The SD card was DEAD. We frantically sourced a new card and spent the night installing Linux and ROS, but then reality hit: I hadn't backed up the final version of our libraries. The only backup I had was a week old, pre dating the final driver fixes. We spent hours trying to rewrite the code from memory, but eventually, the sleep deprivation caught up to us. We had to make the call: it wasn't going to happen. The next day, we went back to the venue and walked the judges through exactly what happened and what we learned. They were incredibly supportive and clearly loved our hardware, but they confirmed we were no longer eligible to compete. We spent the afternoon in the hotel pool to debrief and try to lift our spirits. Lessons learned? I’m never trusting a single SD card again. I’m already investigating the failure to ensure this never happens again. I’m even considering running the OS from an external SSD or keeping a dedicated hardware clone for next time. I was so pumped for this, and the luck just wasn't there. Now, I have exams starting in two weeks. I need to get some sleep, and then it’s straight back to the books. Sid, signing off. Picture taken by me at the Hyderbad airport.

Read Entry →
Messing up ROYALLY.

Messing up ROYALLY.

We needed a custom PCB to integrate all the sensors and the power distribution for the WRO Future Engineers competition. I designed the board in KiCad and even went the extra mile to validate the basic connections by building a physical test version on a prototyping board. I decided a Raspberry Pi Hat was the cleanest way to go. I got the PCB fabbed through JLCPCB and paid for the fastest DHL shipping to make sure we had time. The package arrived in India and was sitting in customs when I got the call: I couldn't receive the package because the phone number provided was invalid. I checked my order, and it turns out I had repeated the last digit of my 10-digit phone number, making it 11 digits. Neither JLCPCB nor I caught the error. With the competition looming, this was a delay we absolutely couldn't afford. There went $40 and a lot of sleep. It was a total unforced error on my part. I’m still trying to stay hopeful, though. We’re currently pivoting to make the prototype board work for the main run. Despite the shipping nightmare, the hardware design itself is solid, and I really love the layout. We should still be able to pull something off. Sid, signing off. Death by a single cut indeed.

Read Entry →